Leander Lauenburg

Leander Lauenburg

About Me

I am a first-year PhD student in the Visual Computing Group (VCG) at Harvard University, advised by Prof. Hanspeter Pfister. I hold a B.Sc. in Engineering Science and an M.Sc. in Robotics, Cognition, and Intelligence from the Technical University of Munich. Before returning to academia I spent several years in industry - at deevio, WATTx, Agile Robots and Merantix Momentum, and most recently as Senior Specialist for AI & Software at DB Systel.

PhD Student | Visual Computing Group, Harvard University

Researching open-source tooling for scalable connectomics and 3D segmentation for emerging image modalities and annotation-scarce settings.
Research Fellow | School of Engineering and Applied Sciences, Harvard University

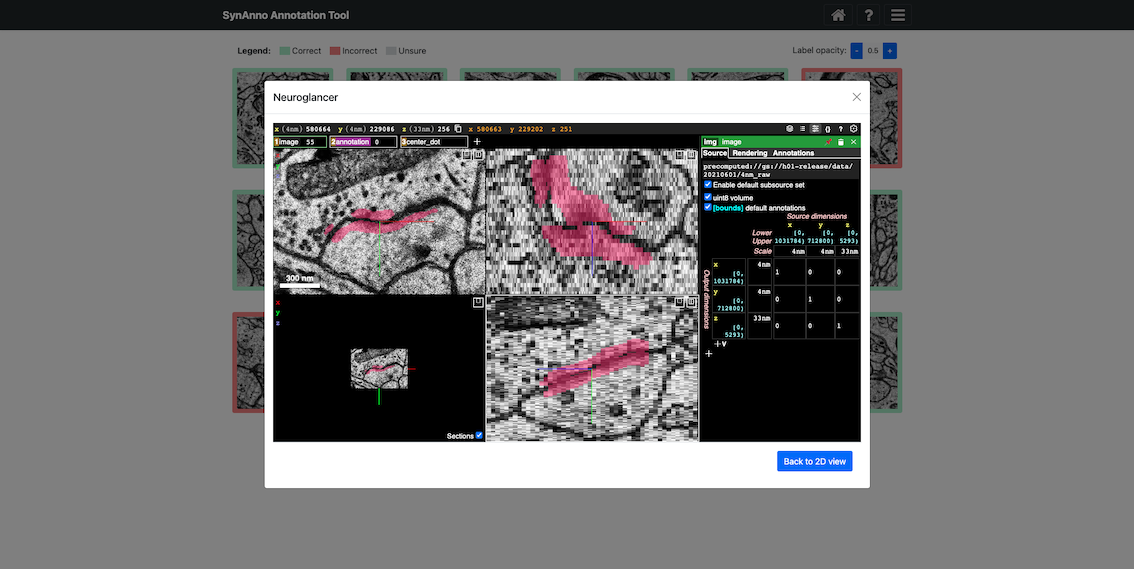
Developed CySGAN for annotation-free cross-modal 3D nuclei segmentation, and started working on SynAnno, an interactive system for proofreading synaptic annotations.

M.Sc. Robotics, Cognition, Intelligence | Technical University of Munich

Thesis: "3D Instance Segmentation of an Unlabeled Modality via Cyclic Segmentation GANs", written during my research stay with the Visual Computing Group at Harvard.

B.Sc. Engineering Science | Technical University of Munich

Thesis: "Energy-based Condition Monitoring for Industry 4.0", written as a student researcher at fortiss.

Publications & Projects

SynAnno

SynAnno: Interactive Guided Proofreading of Synaptic Annotations
Leander Lauenburg, Jakob Troidl, Adam Gohain, Zudi Lin, Hanspeter Pfister, Donglai Wei
(IEEE VIS, 2025)

SynAnno introduces a structured and intuitive approach to proofreading synapses in connectome datasets. I began developing it as a Research Fellow at Harvard University's Visual Computing Group and completed it as a Research Affiliate, alongside my full-time industry role.
Code Preprint IEEE VIS Replicability Stamp

CySGAN

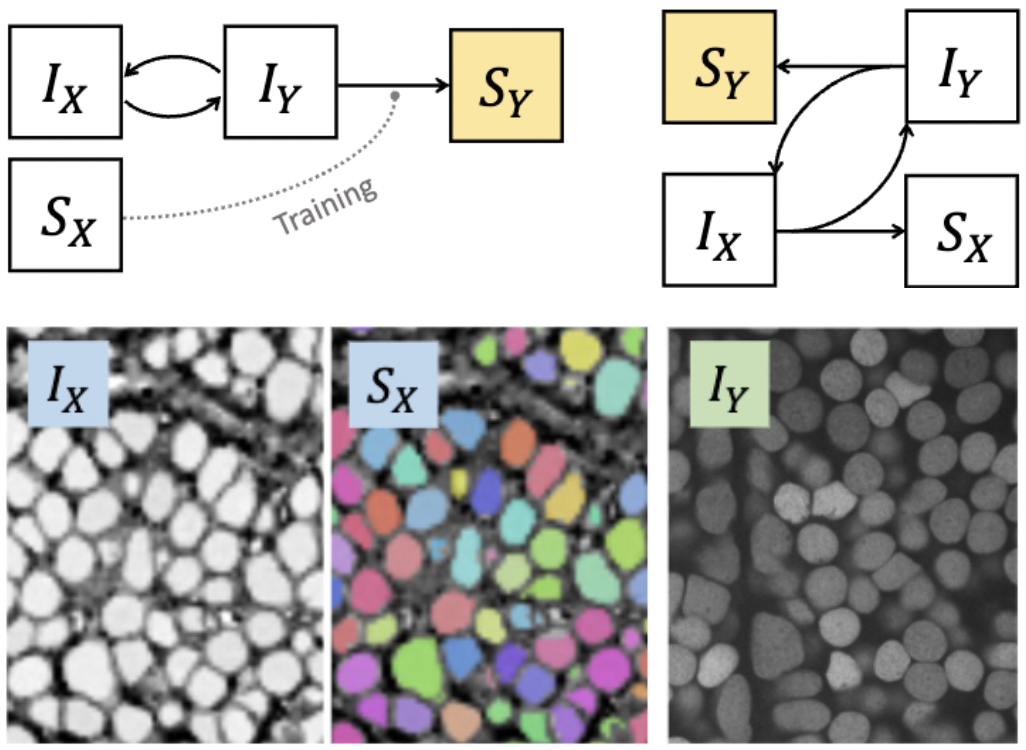
3D Domain Adaptive Instance Segmentation via Cyclic Segmentation GANs
Leander Lauenburg*, Zudi Lin*, Ruihan Zhang, Márcia dos Santos, Siyu Huang, Ignacio Arganda-Carreras, Edward S. Boyden, Hanspeter Pfister, Donglai Wei
(IEEE JBHI, 2023)

The paper '3D Domain Adaptive Instance Segmentation via Cyclic Segmentation GANs', is available via open access in the IEEE Journal of Biomedical and Health Informatics. The paper is the result of my Master's thesis written during my research stay with the Visual Computing Group at Harvard.
Research Code Production Code IEEE JBHI Master's Thesis

Reinforcement learning for robotic reaching

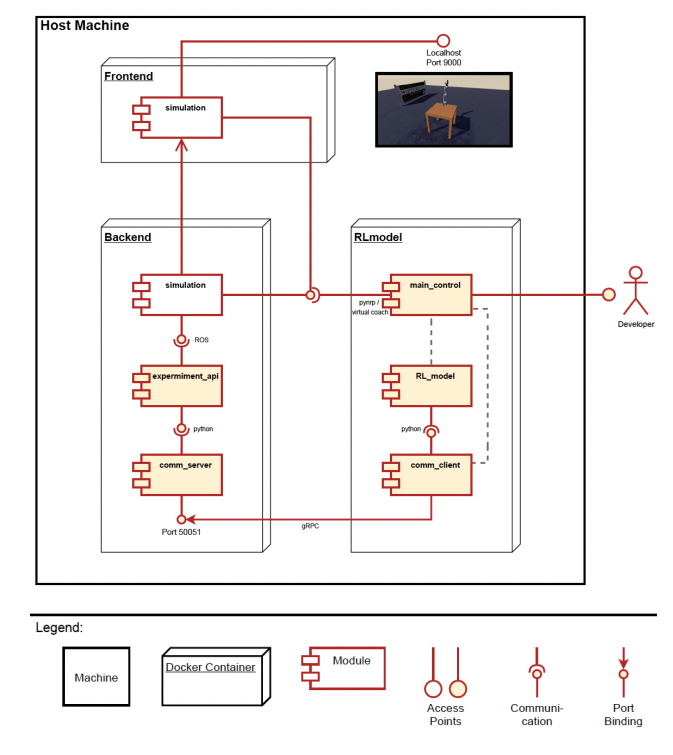
Reinforcement Learning for Solving Robotic Reaching Tasks in the Neurorobotics Platform
Márton Szep, Leander Lauenburg, Kevin Farkas, Xiyan Su, Chuanlong Zang
(HBP Student Conference, 2022)

The paper is my team's contribution to the master course "Cloud-Based Machine Learning in Robotics" (grade 1.0). I presented the work at the 6th Human Brain Project Student Conference.
Code arXiv Paper Conference Abstract

PackLog

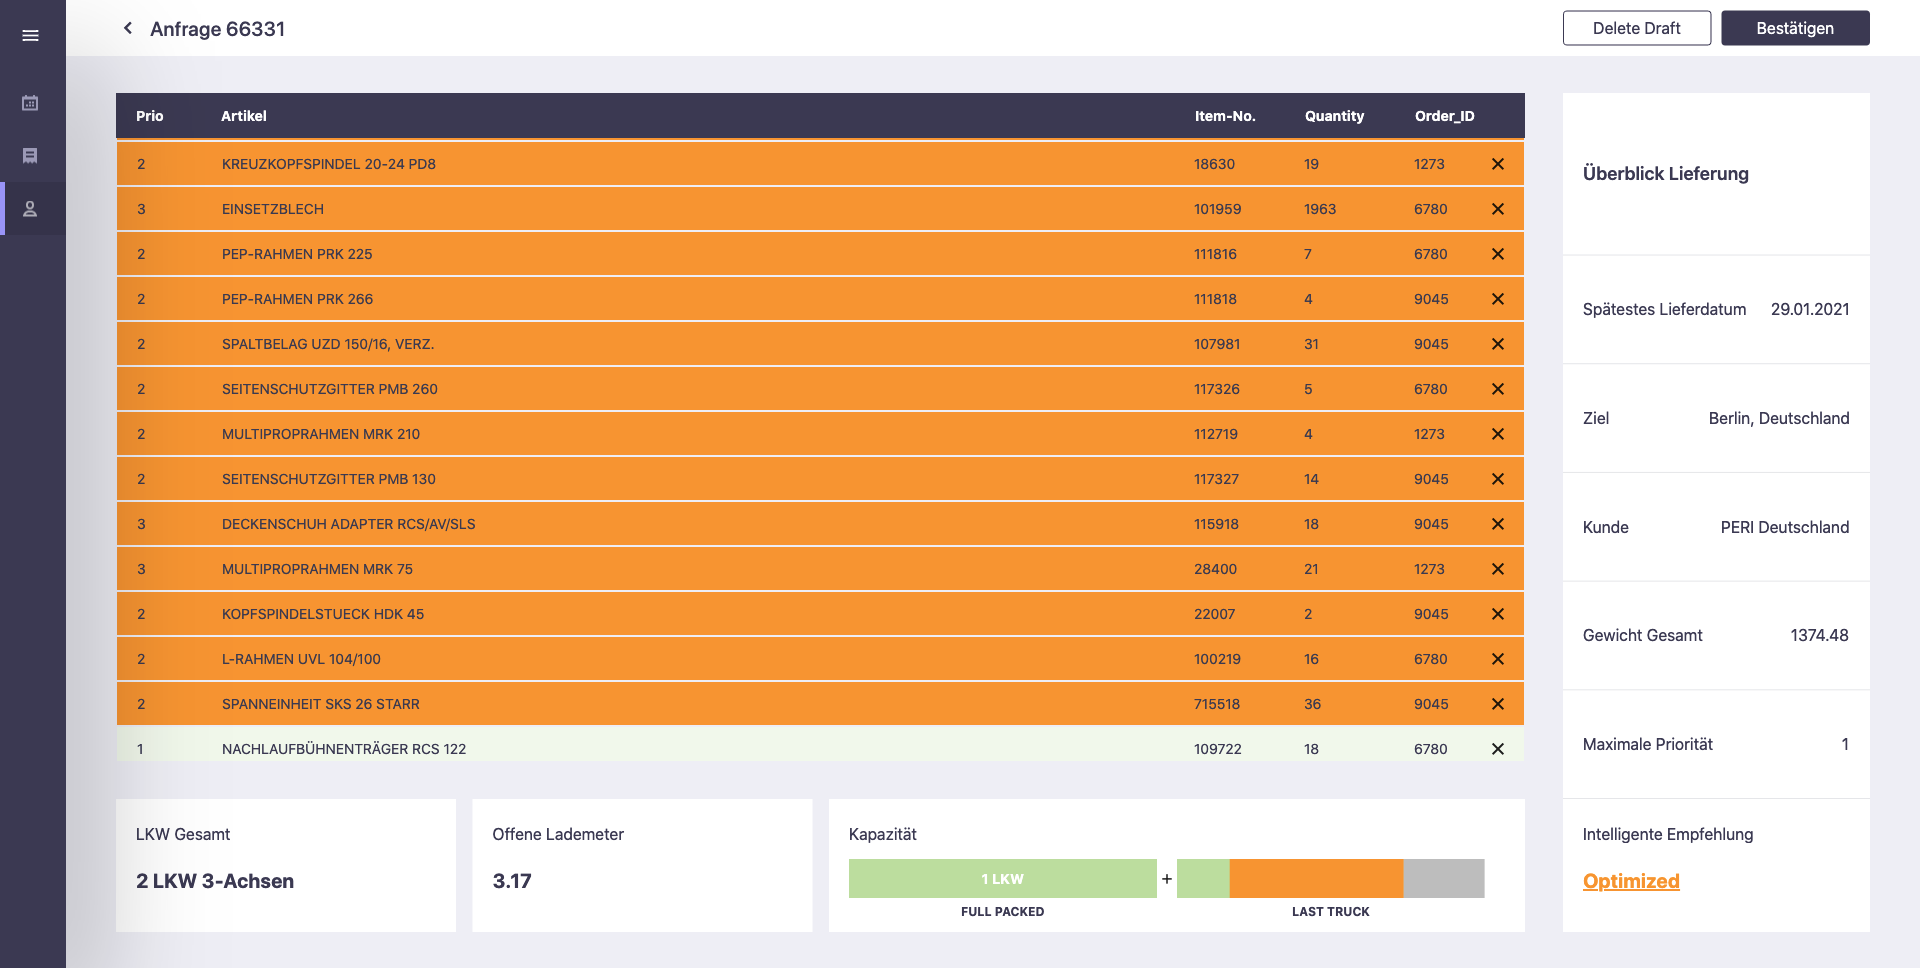
PackLog Solutions: Estimation Tool for Streamlining Logistic Operations
Franz Schubart, Leander Lauenburg, Lukas Pries Marcel, Perez San Blas
(First Place in TechChallenge BEFIVE, Innovation Challenge by UnternehmerTUM, 2021)

In close collaboration with our industry partners, we developed an MVP for streamlining planning and communication processes between the various players in the logistics of large manufacturers.
Code Video

ELA Object SLAM

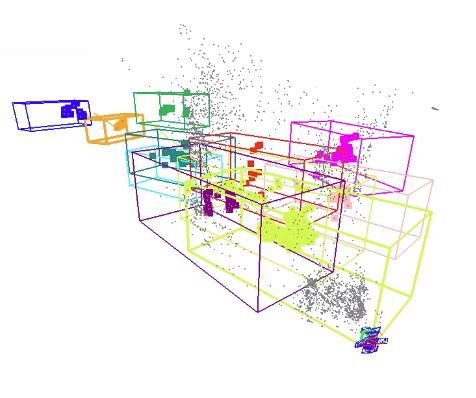
ELA - Object SLAM
Leander Lauenburg, Andy Chen, Ezgi Cakir

The work is my team's contribution to the master course "Advanced Topics in 3D Computer Vision" (grade 1.0). It is an extension of CubeSLAM: Monocular 3D Object SLAM, IEEE Transactions on Robotics 2019, S. Yang, S. Scherer. In addition to cleaning up, streamlining, and dockerizing CubeSLAM, we improved the work by adding dynamic object filtering, object class-dependent scaling, and embedding stream enrichments.
Code

Awards

  • IFI Scholarship (full stipend), German Academic Exchange Service (DAAD), 2022
  • Graphics Replicability Stamp for SynAnno, Graphics Replicability Stamp Initiative, 2025
  • First Place in TechChallenge BEFIVE, Innovation Challenge by UnternehmerTUM, 2021